Professional illustration

Hi, I'm

Hariharan.

RoboticistEngineerExplorer

[ 01 — About ]

WHAT MAKES ME TICK

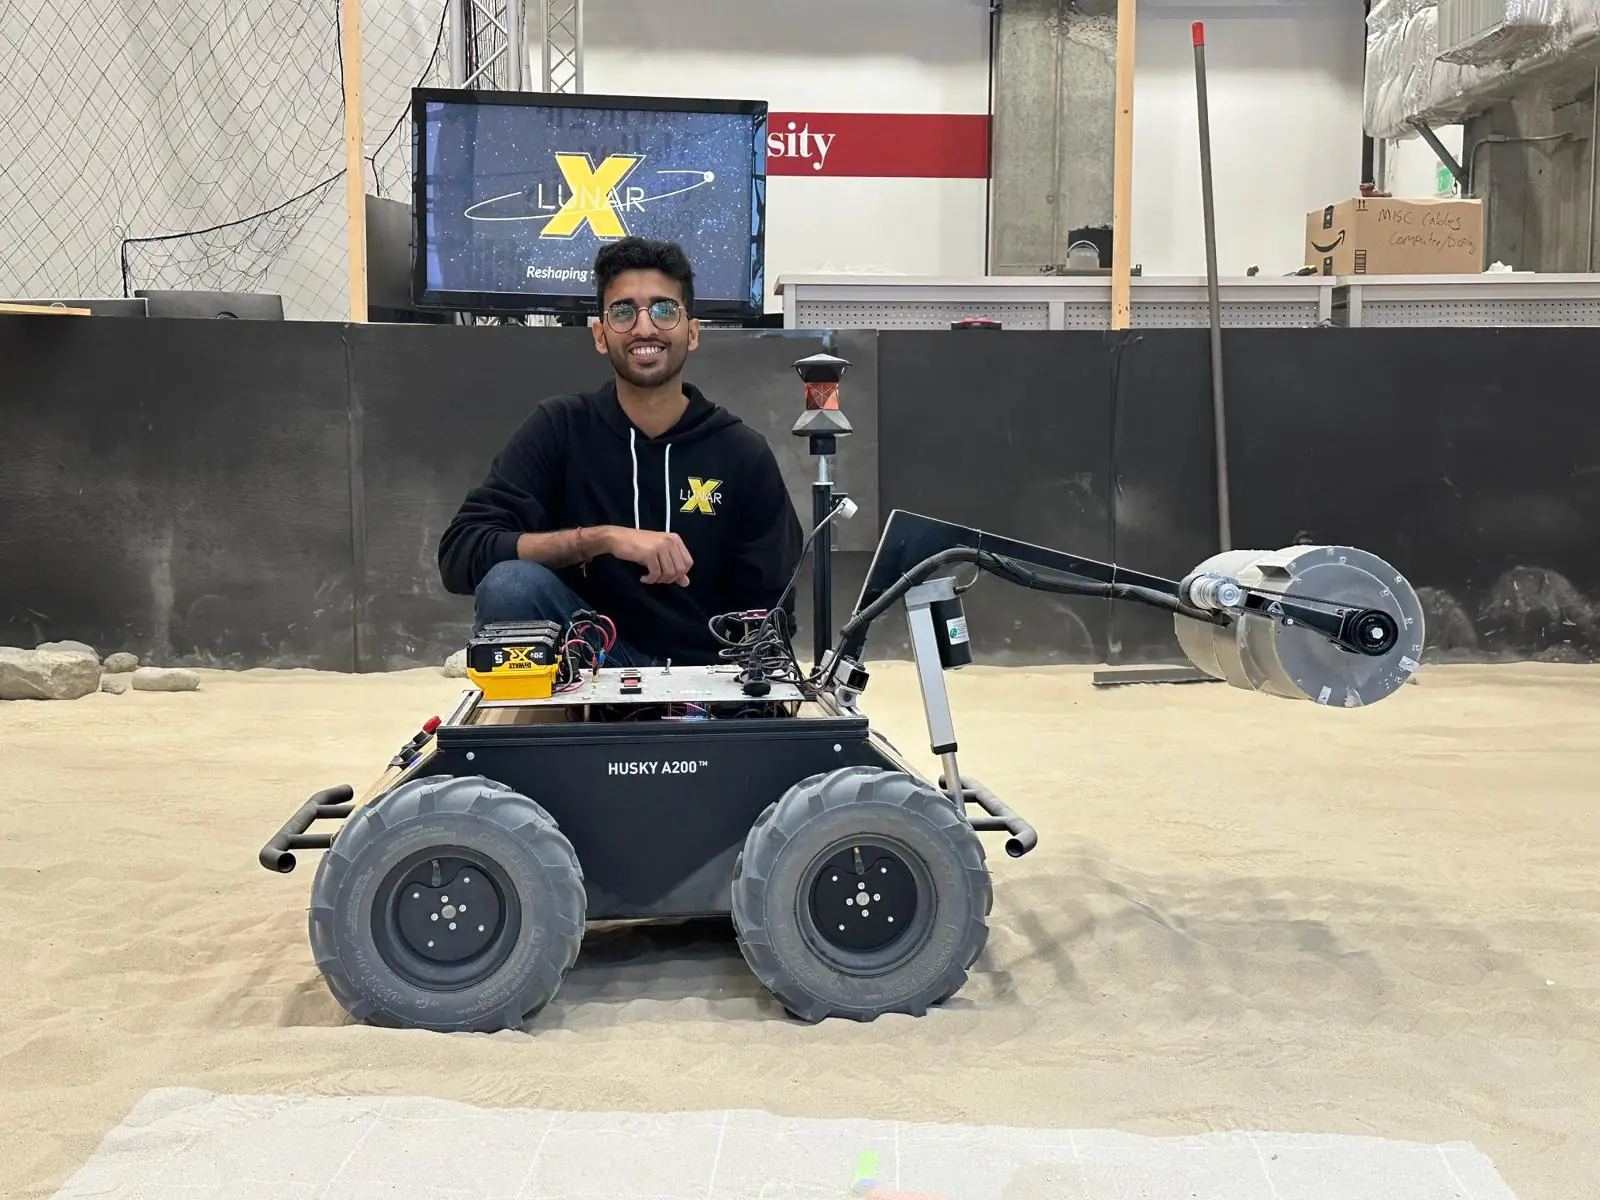
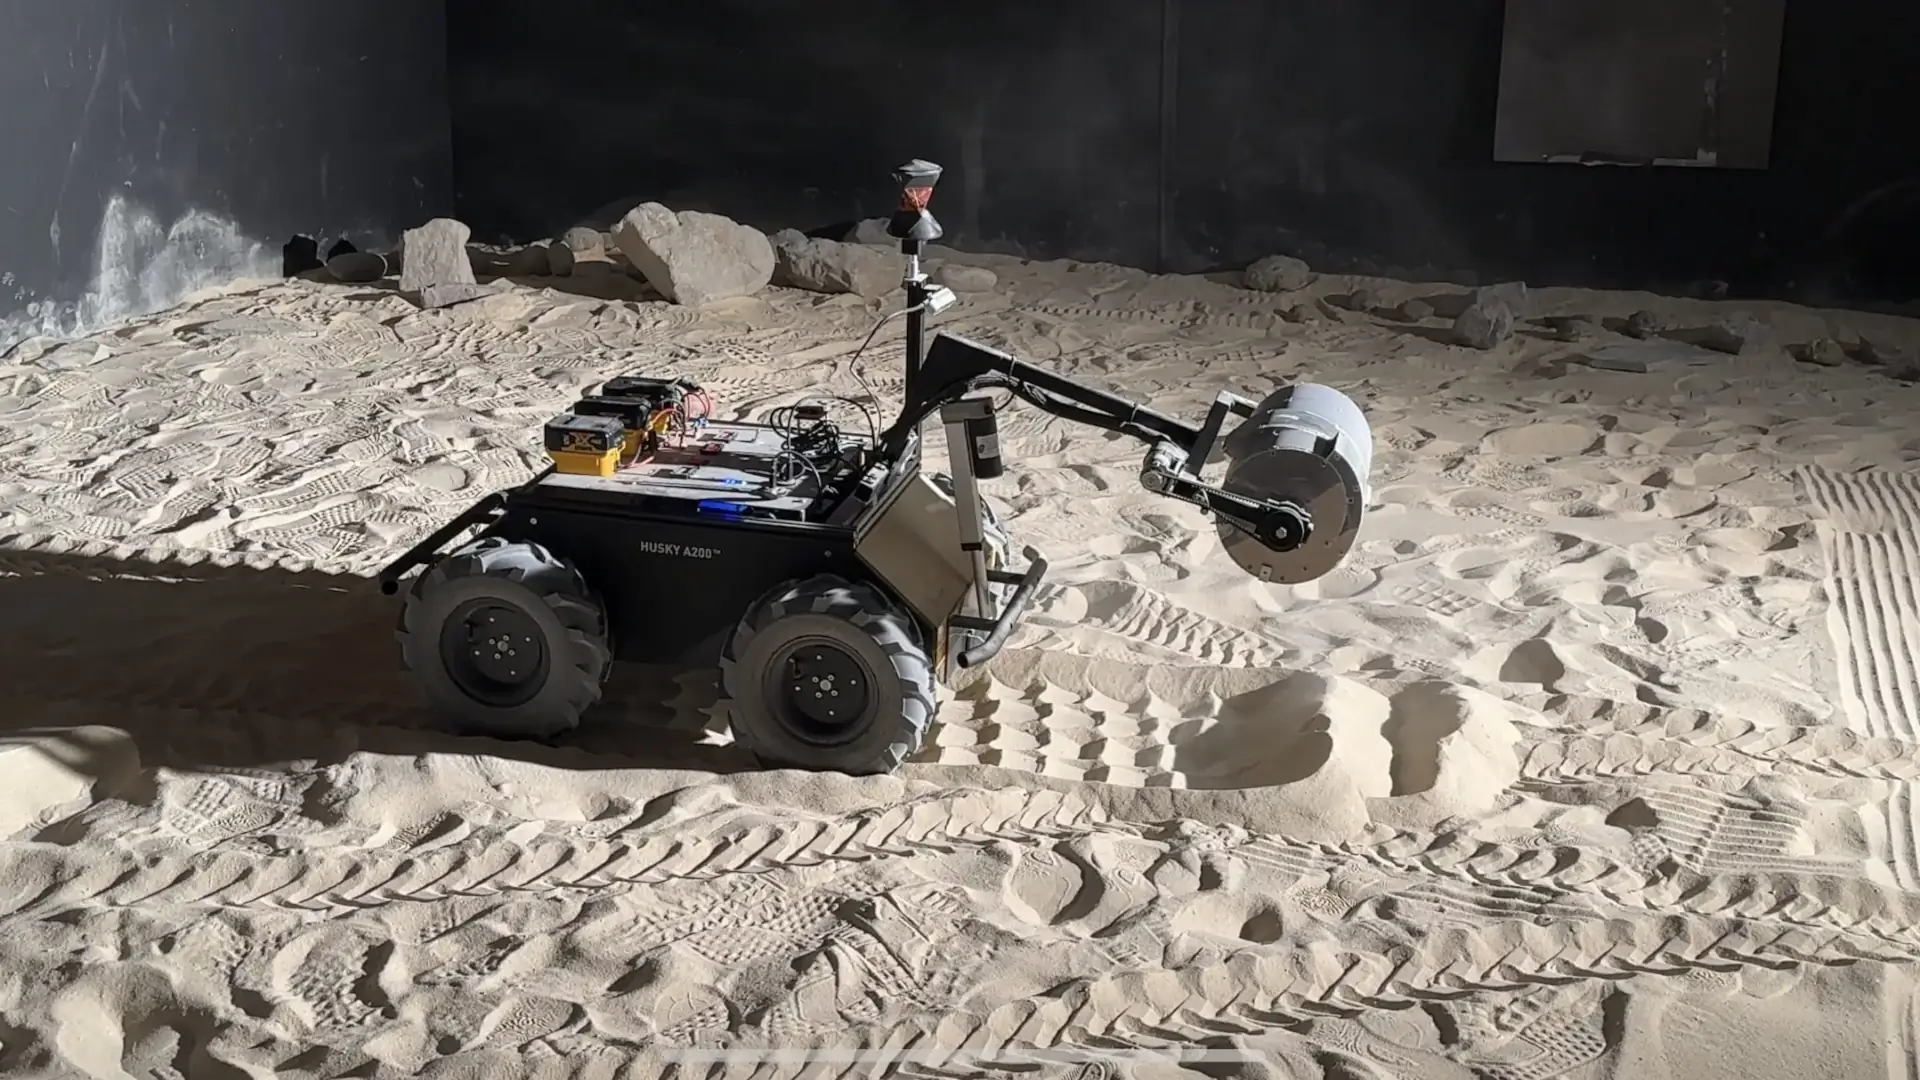
Roboticist at work

Me and the excavator during field testing.
It digs — literally.

Engineering projects

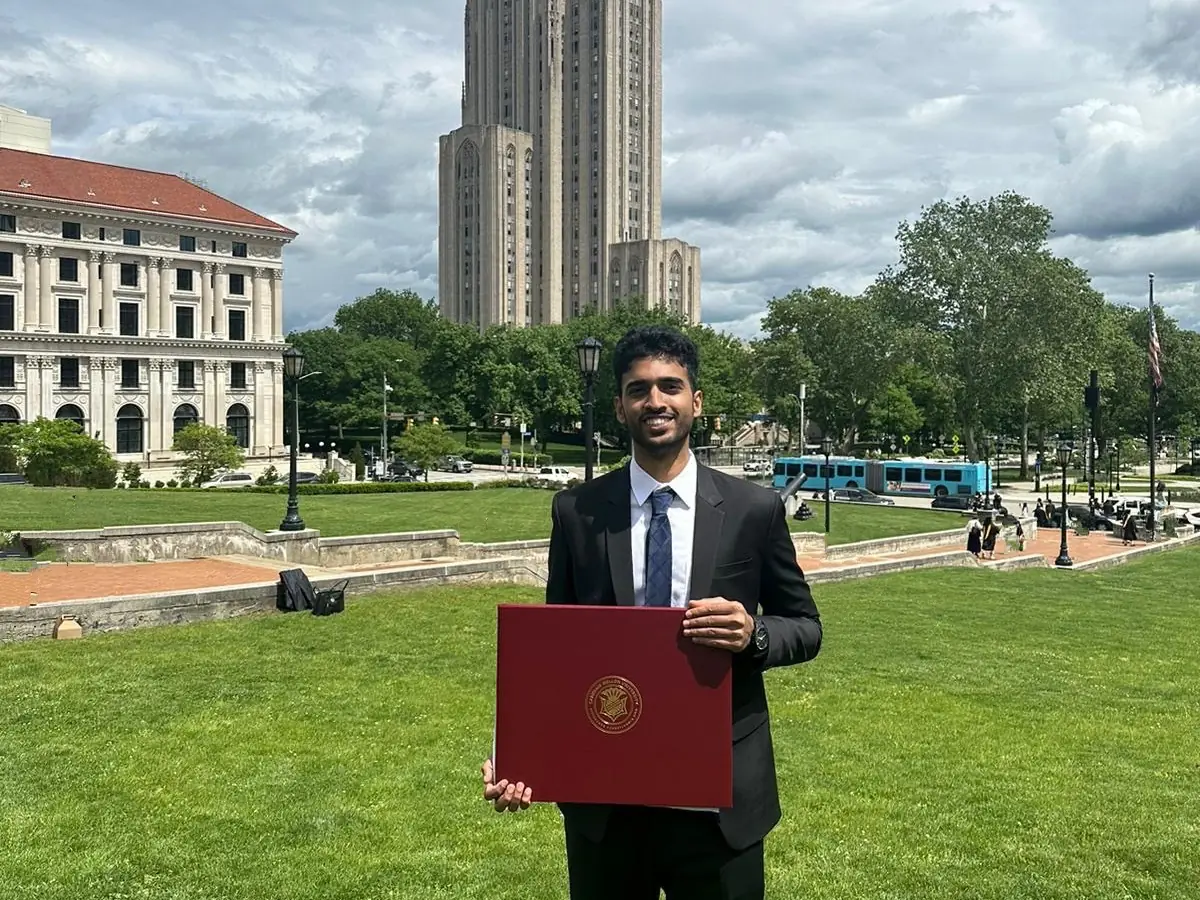
Finally touching grass after graduation.

My Journey into Robotics

I'm a robotics software engineer building software across the robot stack, from high-level behavior and motion planning to controls and firmware. I'm drawn to the work of turning decisions into reliable motion in the real world.

My academic path began with a degree in Aerospace Engineering from IIT Kharagpur, India, where I first got pulled into the world of control systems. That curiosity gradually snowballed into a broader obsession with robotics, leading me to pursue a Master's in Robotic Systems Development at Carnegie Mellon University.

At CMU, I built a strong foundation across the robotics stack, working with hardware, perception, localization, planning, control, and systems integration. Along the way, I discovered a deep interest in motion planning and reinforcement learning, areas where I continue to build expertise.

I currently work as a Robotics Software Engineer III at Nimble, where we’re building robots to make warehouse fulfillment faster and more efficient. I work across the robot stack, from high-level behavior and planning to controls and firmware. Basically, figuring out what the robot should do, how it should move, and getting the hardware to actually cooperate.

Robots, Code, and Everything Between

Previously at Cyngn, I worked as a Senior Software Engineer on the Autonomy team, building the Decision Engine and motion planners for autonomous industrial tuggers. I worked with C++, ROS 2, and BehaviorTree.CPP to help the vehicles figure out what to do next and navigate real-world factory floors, including developing a hybrid A* planner.

Previously at HEBI Robotics, I developed a modular, multi-arm mobile robot with reconfigurable tooling for soil characteristic analysis, built a MuJoCo plugin that lets users run the exact same control code in simulation and on real hardware (demo video), and led the development of the open-source HEBI ROS 2 APIs with support for ROS 2 Control and MoveIt!.

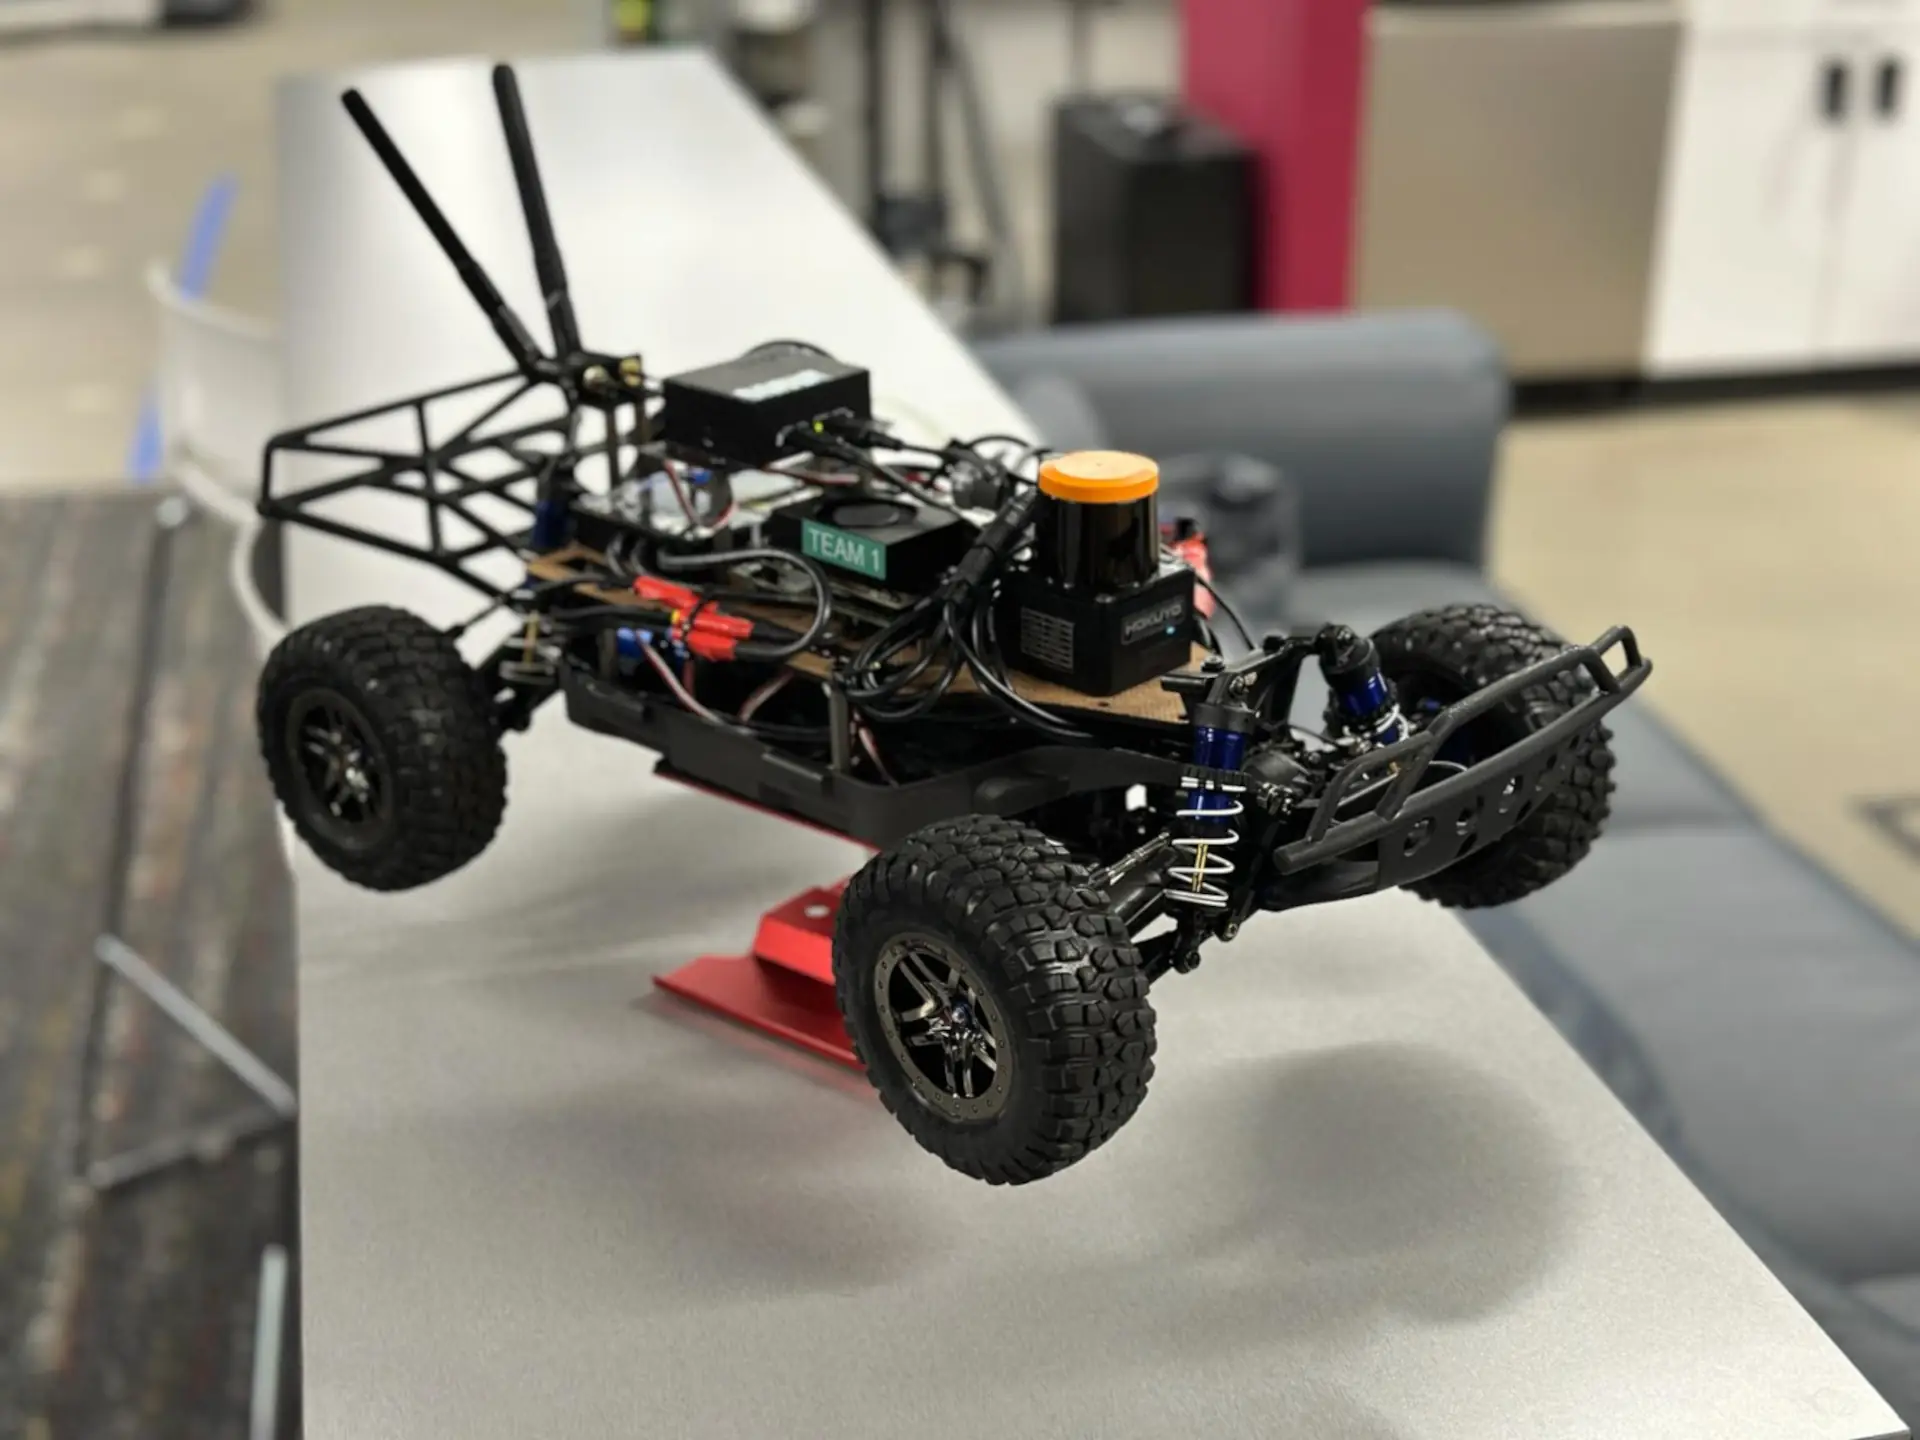
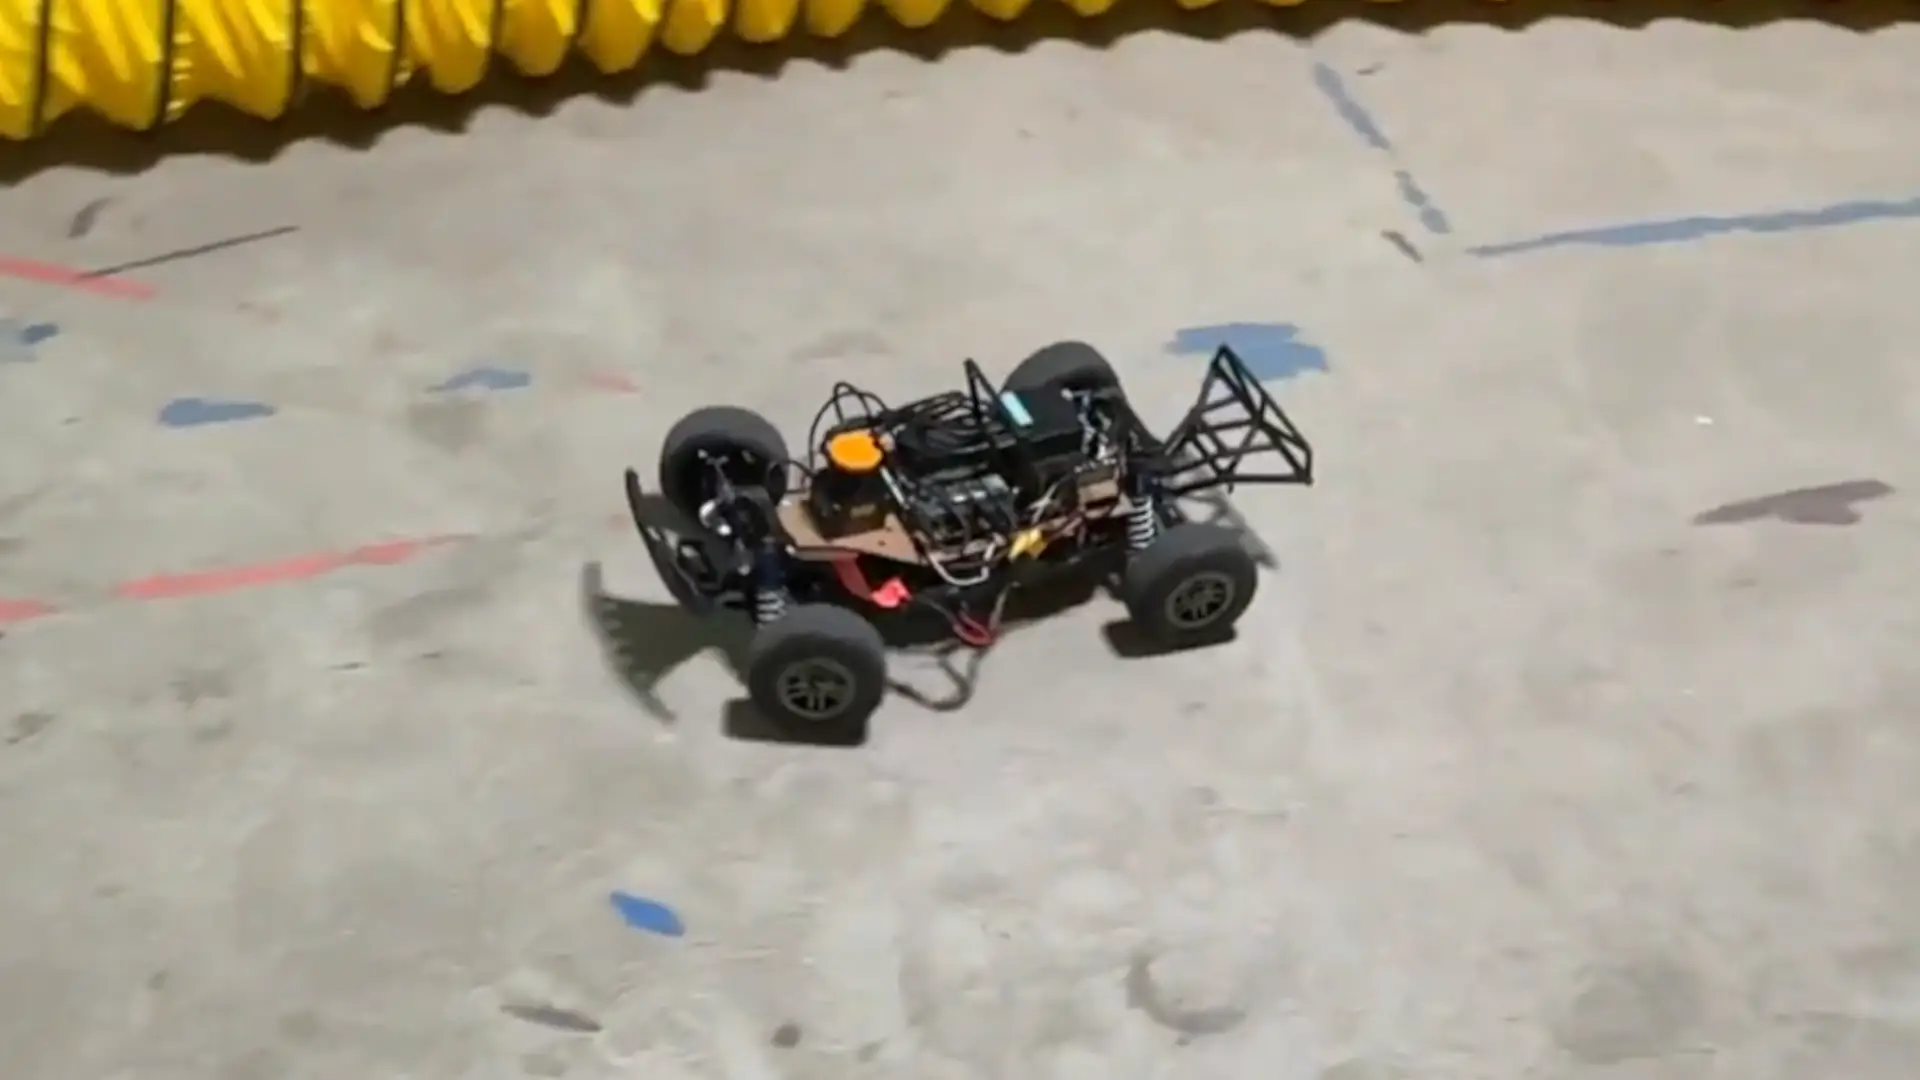
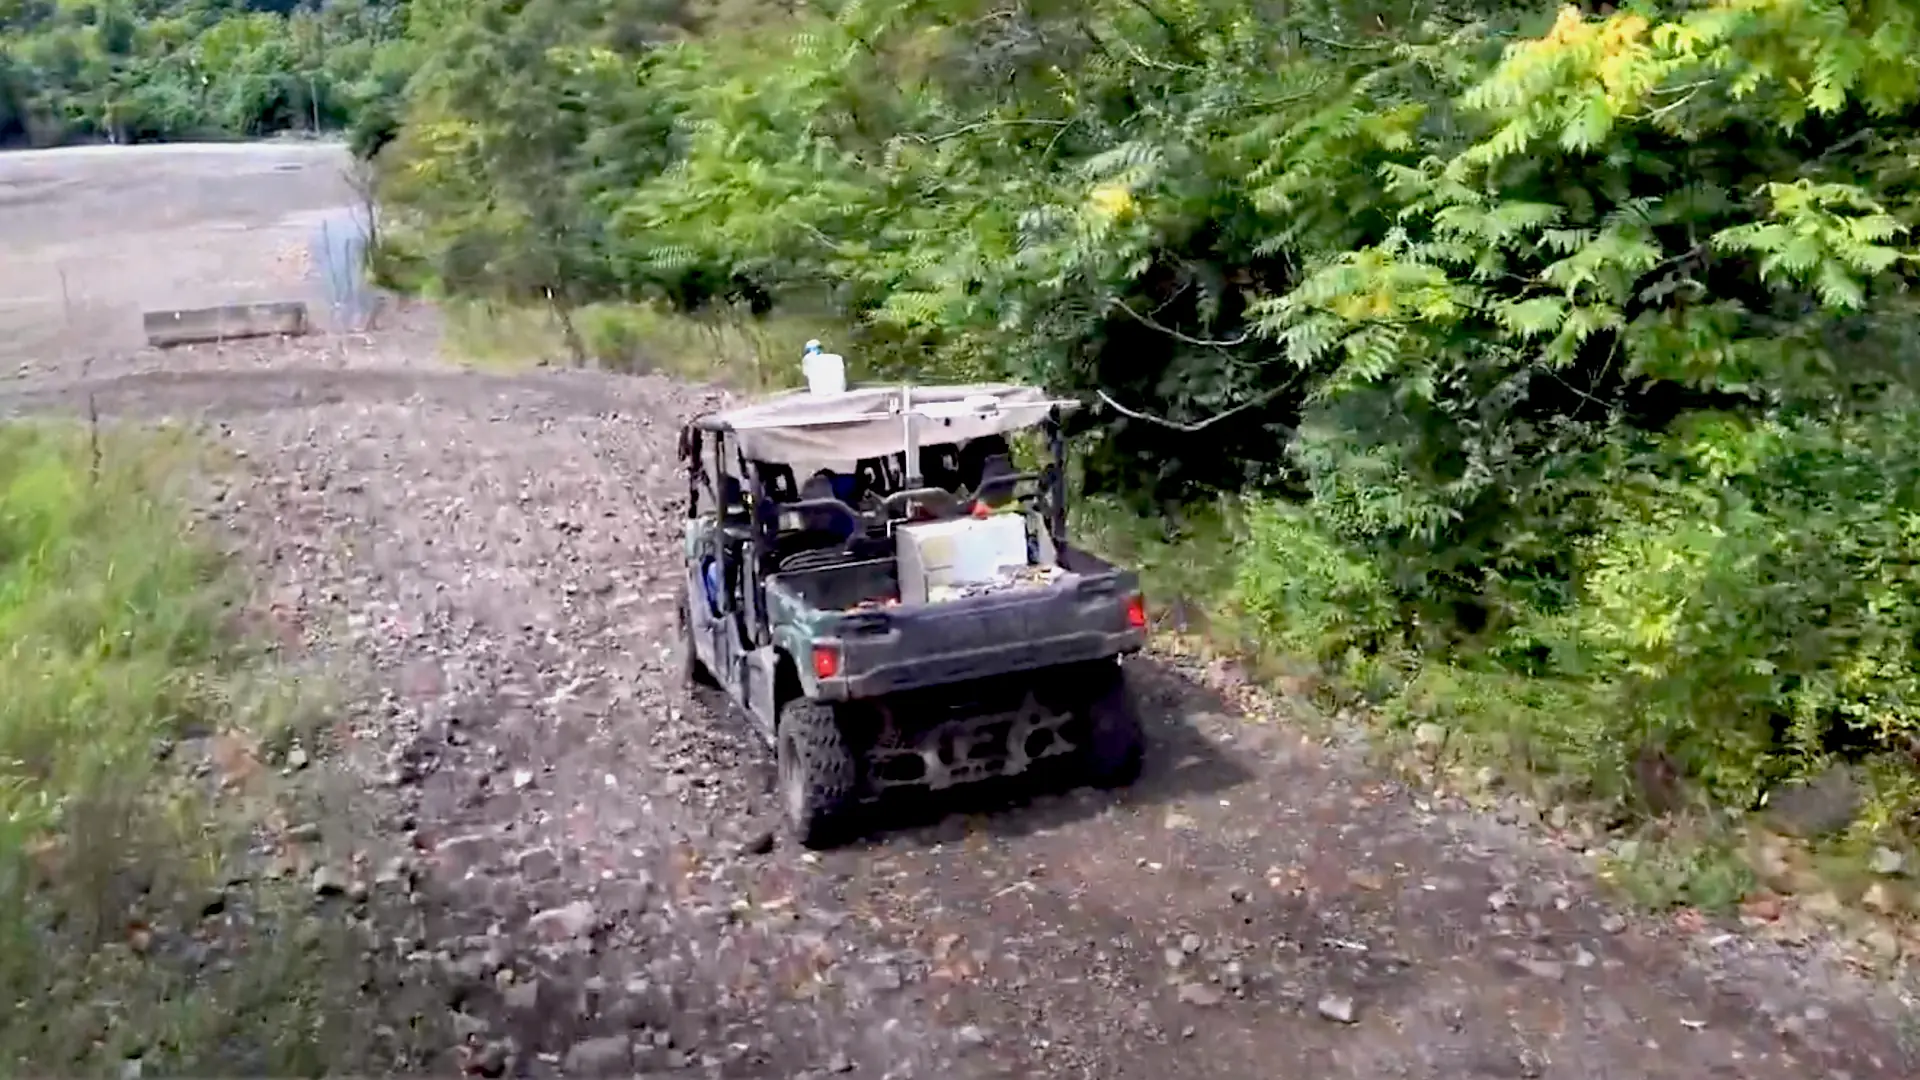
During my time at CMU, I worked on several exciting projects including a lunar-terrain excavation robot as part of my year-long capstone. I also built an autonomy stack for Roboracer (formerly F1Tenth — small racecars, serious autonomy problems) and researched learning-based motion planning for off-road vehicles using self-supervised techniques.

Across all these projects, I've always been drawn to one thing: building autonomy stacks that leave the lab and survive (ideally, thrive) in the messy, unpredictable chaos of the real world. Whether it's behavior planning for industrial robots, data-driven autonomy, or classical motion planning, I enjoy building software that interacts meaningfully with the physical world.

Lately, I've been channeling that same energy into robotics competitions and hackathons, with a few wins along the way. If you want to dig into the technical side of my work, check out the Projects section; for what I'm building and competing in right now, see What I'm Into Lately.

Outside the Lab

Basketball has always been a huge part of my life, and I'm a lifelong Kobe Bryant fan. His work ethic and the way he approached the game still shape how I think about focus, calmness, and discipline, both on and off the court.

I grew up playing the piano and still sit down at the keys whenever I need to reset. Primavera by Ludovico Einaudi is my go-to, partly because it's beautiful and partly because it's the one piece I can still play from memory.

During the pandemic, I picked up chess and have been hooked on 3-minute blitz ever since. It's fast, competitive, and a good way to shift my brain into a different gear.
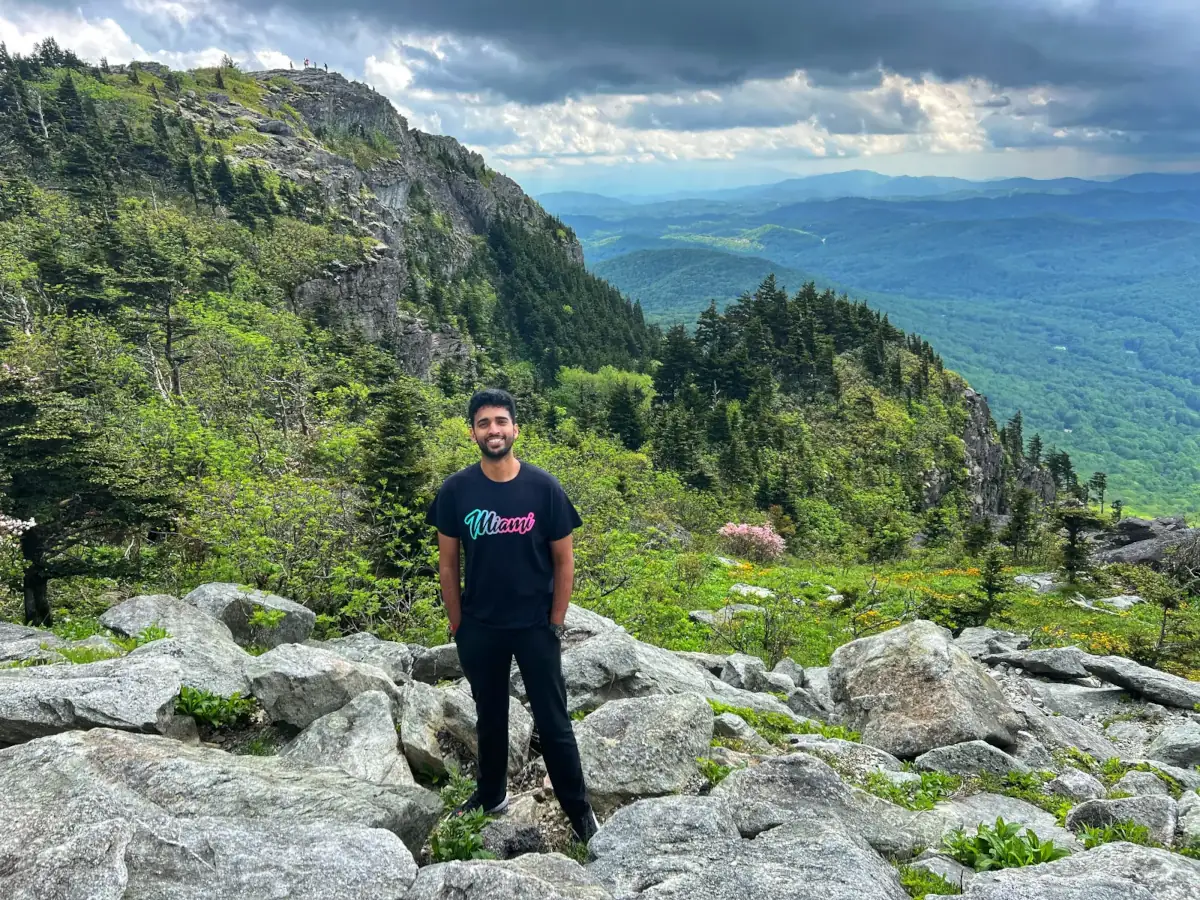
Somewhere in the Appalachian Mountains, escaping from ROS 2 launch files

Off the grid in the Appalachians, where ROS 2 launch files can't reach me.

[ 02 — Projects ]

WHAT I'VE BUILT

Imperative Learning-Based Planning for Offroad Driving

Imperative Learning-Based Planning for Offroad Driving

A gradient-optimized local planner for goal-directed navigation on unstructured terrain

ResearchProjectOffroad
Optimal Control Framework for Hybrid VTOL tilt-rotor UAV

Optimal Control Framework for Hybrid VTOL tilt-rotor UAV

Stabilizing tilt-rotor transitions using optimal control strategies under nonlinear dynamic conditions

CourseProjectOptimalControlAerospace
Multi-Agent Planning in Reconfigurable Environments

Multi-Agent Planning in Reconfigurable Environments

Planning strategies for collaborative robot fleets in environments that can be altered by the agents

MAPFCourseProjectCollaborativeRobotics

[ 03 — Now ]

WHAT I'M INTO LATELY

Last updated: Oct 12, 2026

New job, new robots! I recently joined Nimble, and I’m excited to get hands-on with a different set of robotics problems. There’s plenty to learn, a new team to get to know, and firmware to get reacquainted with. Outside of work, this year has also brought a fair share of robotics competitions, hackathons, and side projects.

  • Qualified for Phase 1 of the Intrinsic AI for Industry Challenge with team HexDex, ranking 12th out of 160+ teams (1000+ participants). The challenge, run by Intrinsic (Alphabet's robotics-software company), targets dexterous electronics assembly: perceiving, grasping, and inserting cable connectors with the right amount of force. We qualified using classical approaches in Gazebo, and for Phase 1 we're moving into Intrinsic's Flowstate environment, where we aim to bring in learning-based methods.
  • Selected for Y Combinator's Startup School 2026, a hand-picked, in-person cohort of builders in San Francisco.
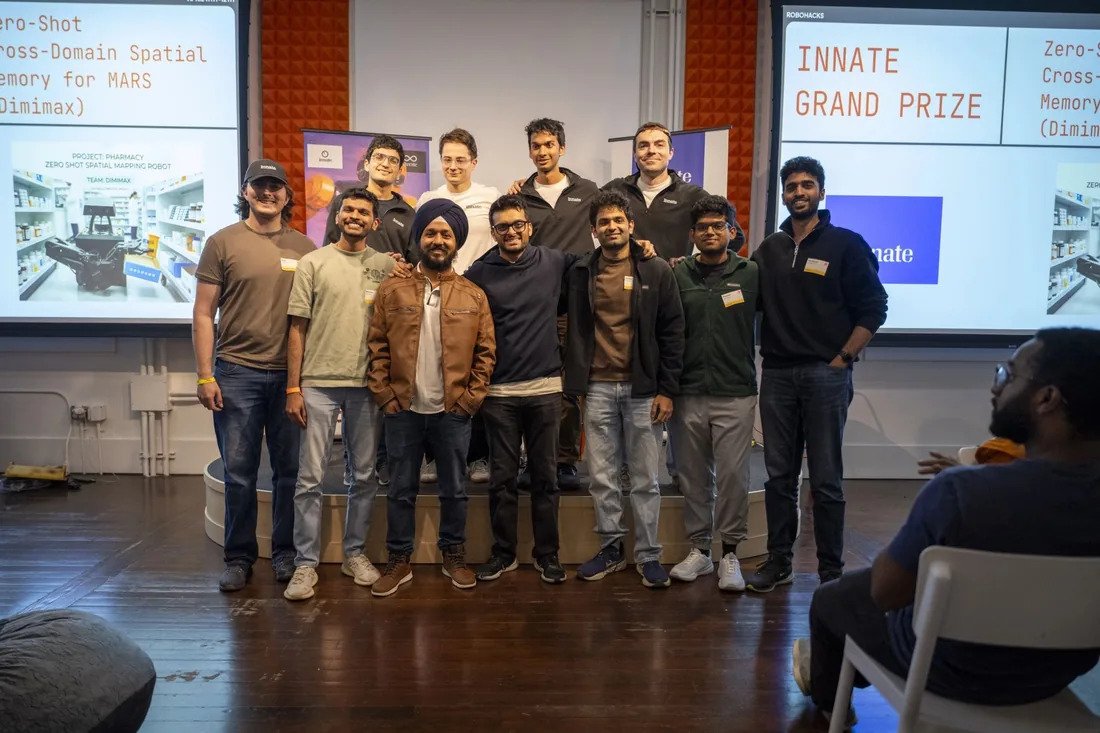
  • Team Dimimax on stage at RoboHacks @ Y Combinator after winning the Innate Grand Prize
    Team Dimimax at RoboHacks @ Y Combinator.
    Won the Innate Grand Prize and Best Use of Data at RoboHacks @ Y Combinator. My team built Dimimax, a zero-shot spatial memory layer that lets a general-purpose robot understand and navigate a brand-new environment. For the demo, we deployed it in a mock pharmacy, where it read customer prescriptions and picked the right medicines for them end to end. Built on Innate's MARS robot alongside Praveen, Jash, Naman, Jaskaran, and Debajit. I've since brought a MARS unit home to keep building on it.
  • Earlier, I raced the RoboRacer Sim Racing League as Team Mamba (1st in qualification, 2nd in the final) and contributed the Austria F1 track to the open-source RoboRacer simulator.
  • Judged the FIRST Robotics CA District Silicon Valley Event presented by Apple. It was my first FRC event, and I came away genuinely impressed by what these high-school teams are building. I'll be back.

When I'm not building, I've been exploring California, chasing sunsets from clifftops and making the most of the sun after a few gray Pittsburgh winters.

[ 04 — Contact ]

LET'S TALK

Whether you want to talk robotics, autonomy, and physical AI, trade California hike recommendations, debate the NBA playoffs, or just say hi, I'd love to hear from you. Reach me on any of the platforms below.

Relaxing with a laptop on a sofa beside a chess-playing robot arm, a basketball, and a small rover Relaxing with a laptop on a sofa beside a chess-playing robot arm, a basketball, and a small rover